Robotic Automation
We don't supply robots. We engineer robotic applications.
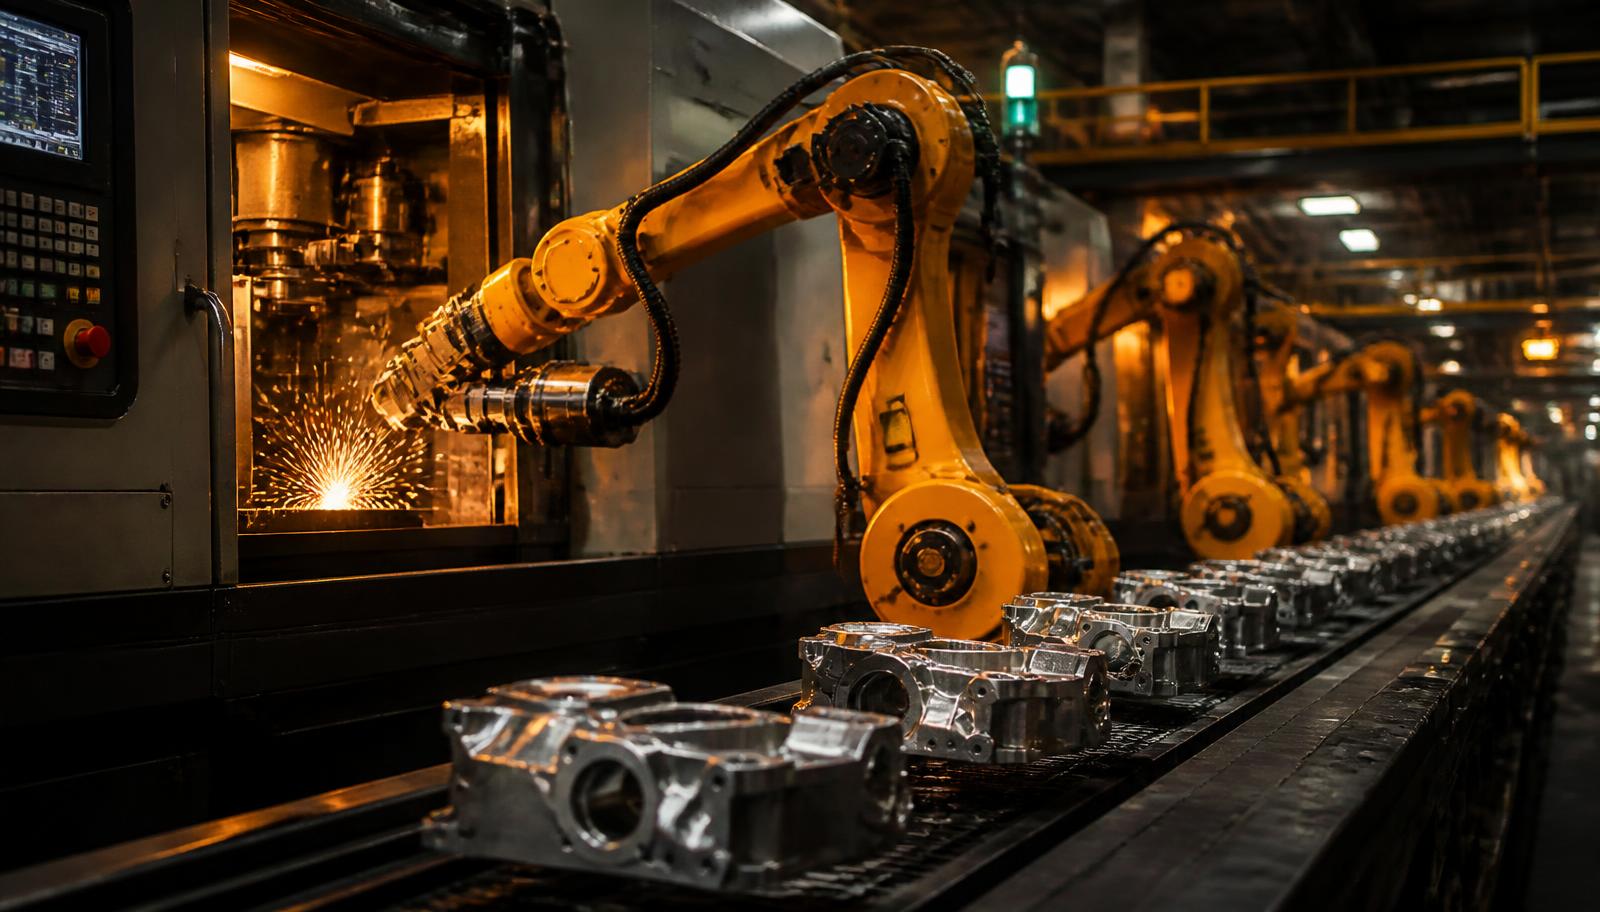
Robotic palletizing, depalletizing, pick and place, machine tending, material handling, packaging automation, inspection integration and custom robotic cells — specified from your cycle time, payload and layout, not from a brochure.
- Infeed 01
- Buffer 02
- Robot cell 03
- EOAT 04
- Safety 05
- Outfeed 06
The challenge
Why robot projects underperform.
A robot is only as good as the application engineering around it: tooling, infeed, cycle time and safety layout.
- Cycle time defined by the application, not by robot specification alone
- End-of-arm tooling that must handle multiple product formats reliably
- Infeed presentation that is inconsistent or unbuffered
- Safety layout and access requirements inside limited floor space
- Integration with existing machines, controls and plant conventions
The solution
The cell is designed around the operation.
We define the application first — product, rate, reach, tooling and safety — and then select and integrate the robot that fits it.
- Application study with reach, payload and cycle-time verification
- Custom end-of-arm tooling designed for the product and format range
- Infeed and outfeed conveying engineered with the cell, not after it
- Risk-assessment-led safety design: fencing, scanners, interlocks, muting
- Controls integration with plant PLC, HMI conventions and data handshake
How the system works
From application to running cell
- Application definition: product, rate, pattern and constraints 01
- Reach, payload and cycle-time study with layout concept 02
- Tooling and cell design — mechanical, electrical, controls, safety 03
- Build, wiring, programming and factory testing of the cell 04
- Site installation, integration with adjacent machines 05
- Commissioning, safety validation and operator training 06
System components
What the engineered system includes.
Industrial robot
End-of-arm tooling
Infeed / outfeed conveying
Sensing & vision
Safety system
Controls & HMI
Industries
Where this is applied.
- Pharmaceutical carton, case and product handling
- Food and FMCG packaging and palletizing
- Tyre and heavy component handling
- Automotive machine loading and unloading
Design inputs
What we need to design the system.
Sharing these upfront lets us respond with a concept instead of a questionnaire.
- Product weight, dimensions, orientation and gripping surface
- Required rate (picks or cases per minute) and shift pattern
- Layout with available footprint, height and access clearances
- Existing machine interfaces and controls platform
- Safety expectations and plant standards
Technical FAQ
Questions engineering teams ask us.
Q Which robotic applications do you engineer?
Robotic palletizing, depalletizing, pick and place, machine tending, material handling, packaging automation, inspection integration and custom robotic cells for manufacturing plants.
Q How is a robotic cell specified?
From payload, reach, required rate, product presentation and layout constraints. These determine the robot class, tooling design, conveying and safety layout.
Q Do you handle safety compliance?
Cell design follows a risk assessment. Guarding, interlocks, scanners and safe access are engineered into the layout and validated during commissioning.
Q Can a robotic cell handle multiple SKUs?
Yes, when the SKU range is defined at concept stage. Tooling and recipes are designed for that range so changeover is a selection, not a rebuild.
Describe the operation you want a robot to perform.
Send your line layout, product data and current cycle time. We will revert with a preliminary automation concept.